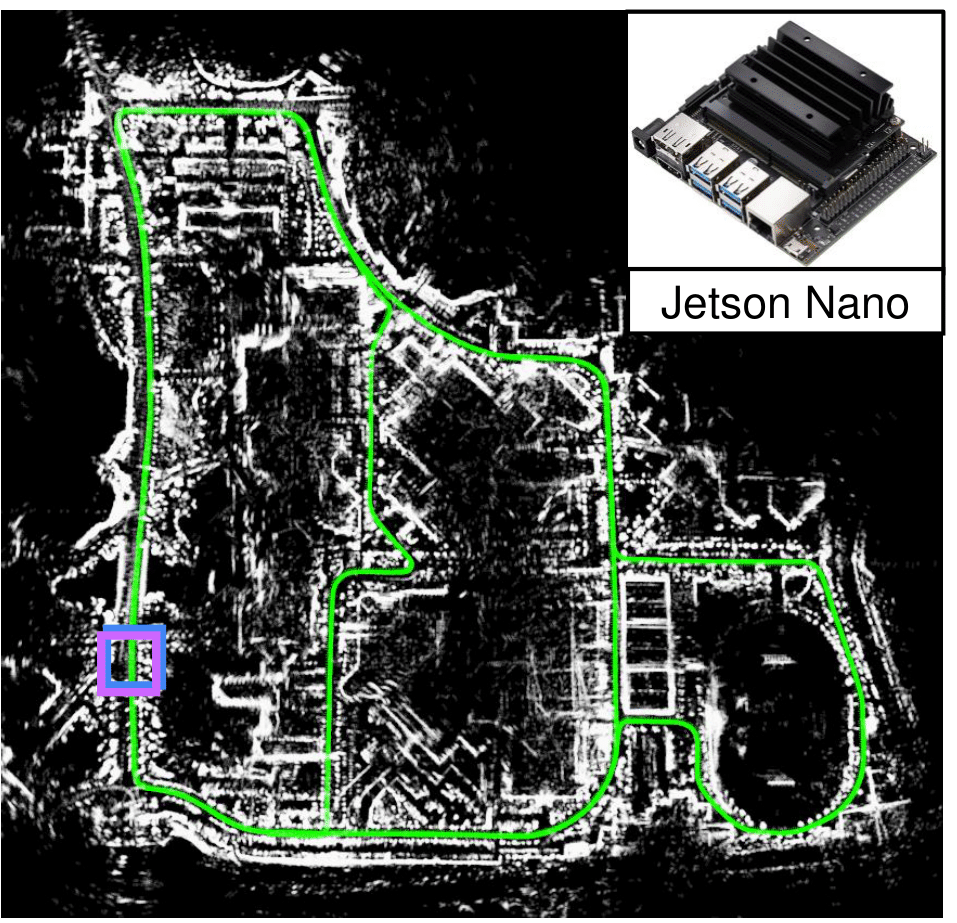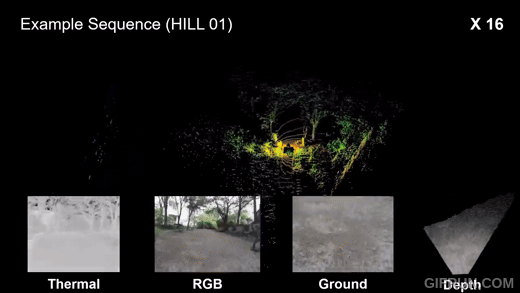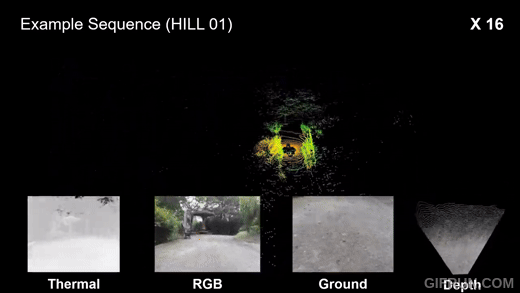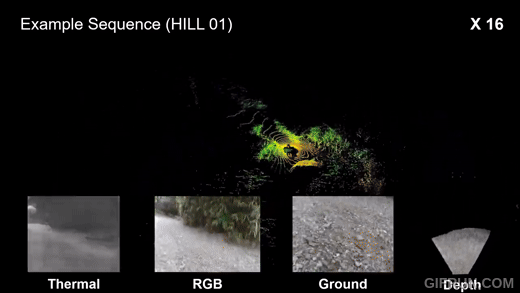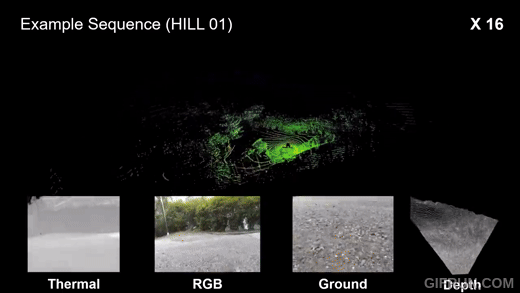
SKiD-SLAM: Resource-Aware Distributed Multi-Robot LiDAR SLAM for Planetary Missions with Field Deployments at Analog Sites
IEEE Transactions on Field Robotics (T-FR 2026)
Resource-Aware Distributed Multi-Robot LiDAR SLAM for Planetary Missions
Scalable and collaborative autonomy for multi-robot systems
I'm a Ph.D. student in the Department of Electrical and Computer Engineering at Inha University, advised by Younggun Cho in SPARO Lab. I also received my B.S. in Naval Architecture and Ocean Engineering from Inha University. My research focuses on scalable and collaborative robot autonomy in multi-robot systems, studying how robots perceive, map, and operate in shared environments through communication-efficient coordination and interaction. For my personal thoughts and research experiences, please check out my Posts :)
News
Research
My main line of work is multi-robot SLAM: helping a team of robots build one consistent map under limited bandwidth and computing. These papers cover lightweight place recognition for finding shared places, communication-efficient map merging, and distributed SLAM deployed in the field.
Research Thread
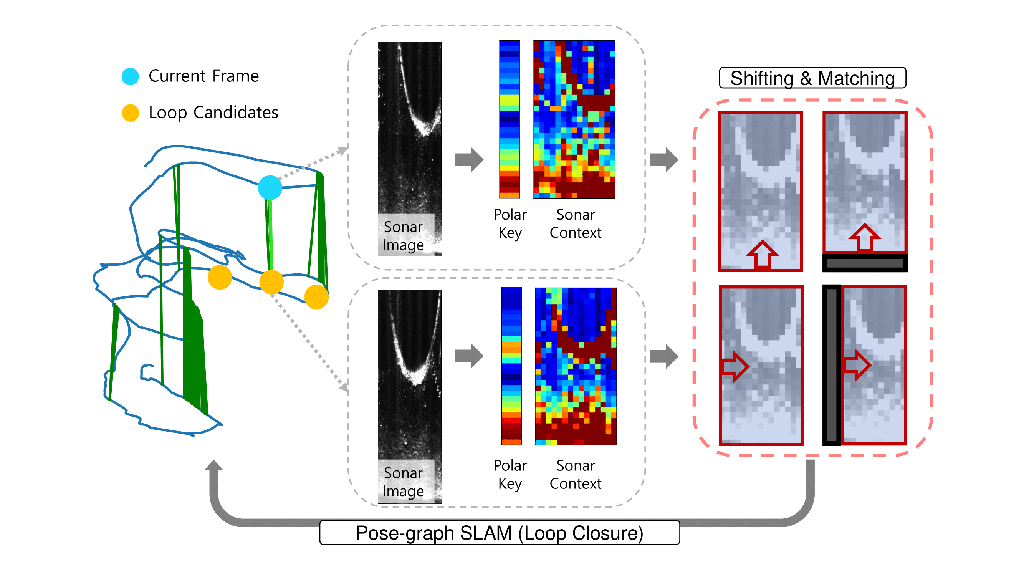
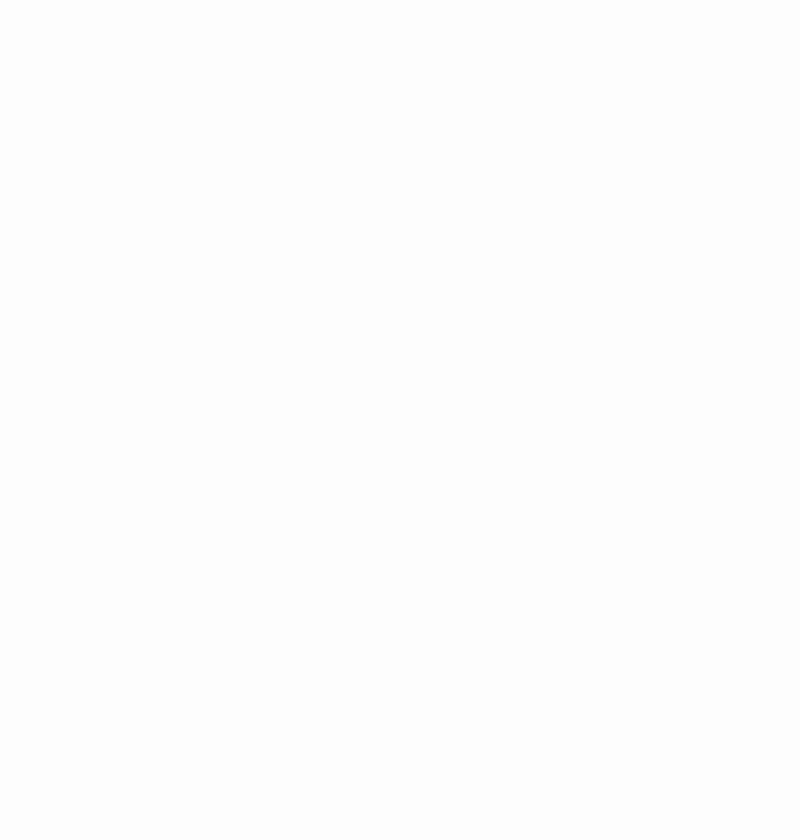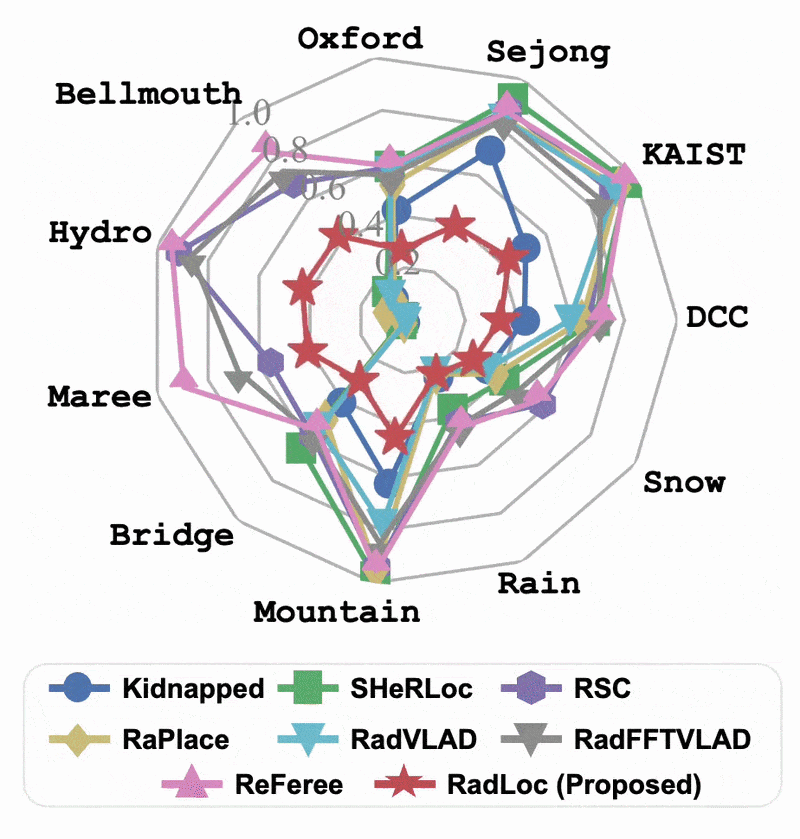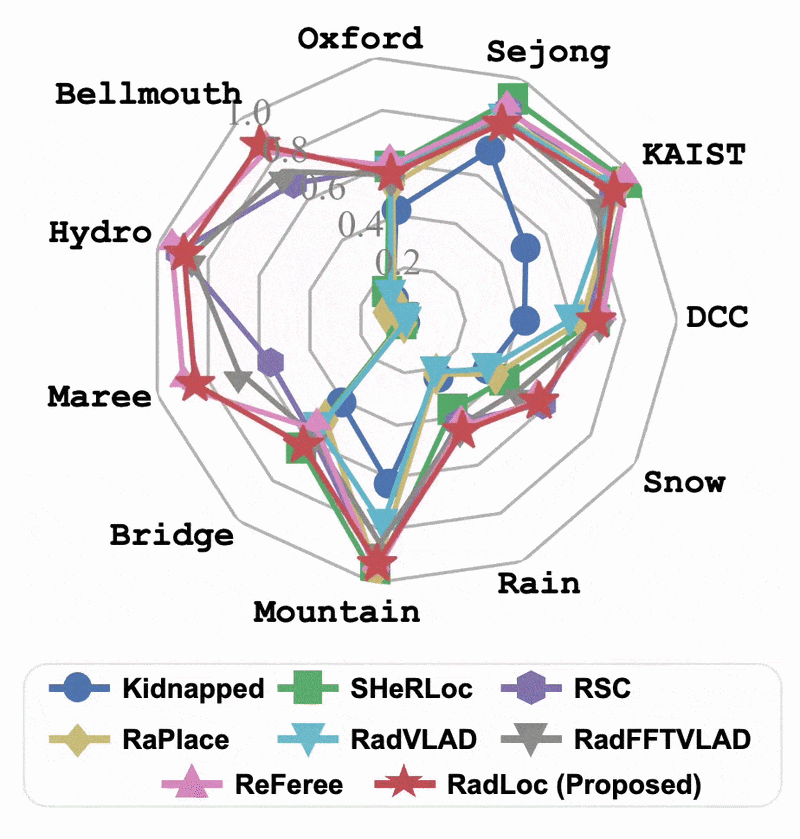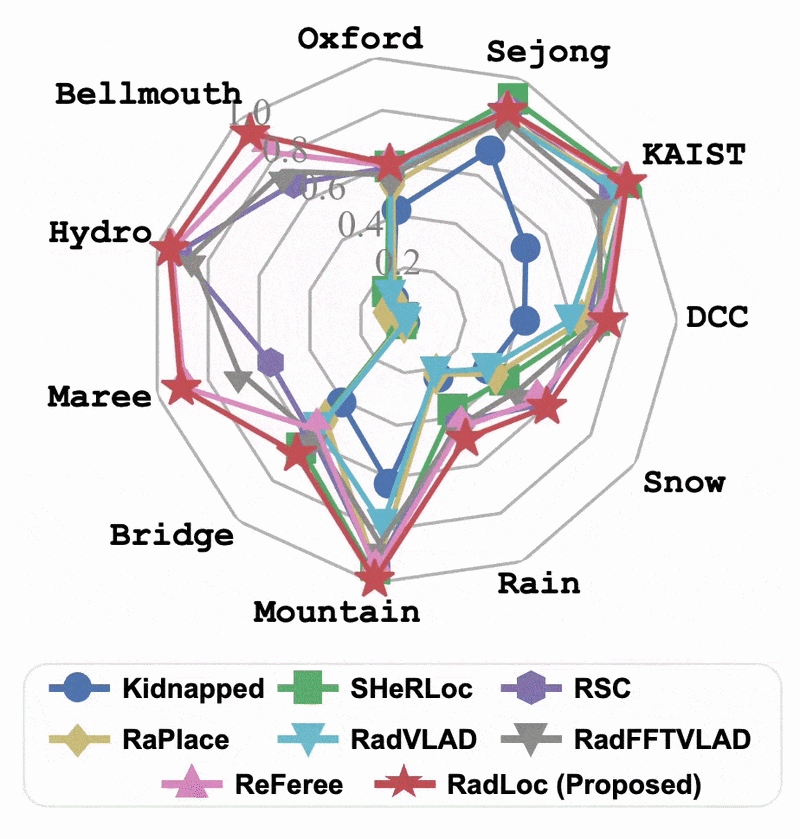
Radar sees through rain, snow, fog, and dust, but its scans are full of speckle and multipath. I build radar place recognition and global localization that stay lightweight enough to share between robots, as a step toward radar-based multi-robot SLAM.
Research
My research interests lie in multi-robot systems spanning both robot autonomy and interaction. To date, my work has focused on multi-robot SLAM and place recognition for shared environmental perception, with an emphasis on communication-efficient knowledge mapping and sharing. Selected papers are highlighted.

IEEE Transactions on Field Robotics (T-FR 2026)
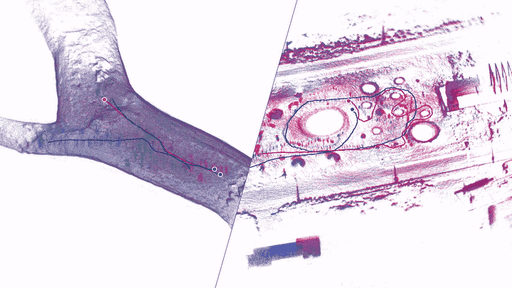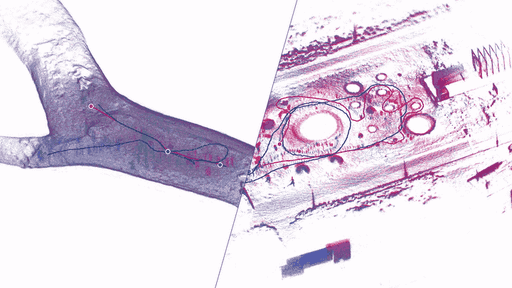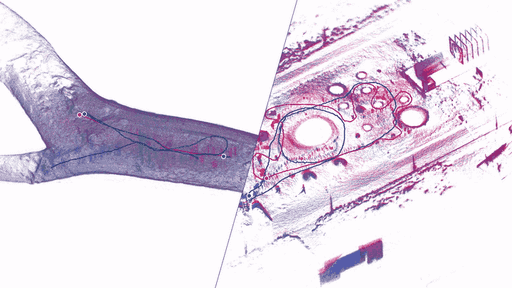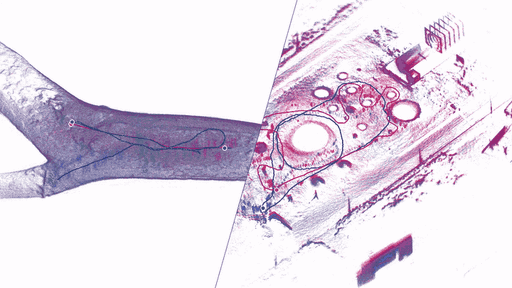
Resource-Aware Distributed Multi-Robot LiDAR SLAM for Planetary Missions

International Journal of Robotics Research (IJRR 2026)
Samsung HumanTech Silver Award
Communication-Efficient Multi-Robot Map Merging Framework

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026)
Radar-based 3-DoF Global Localization


IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2025)
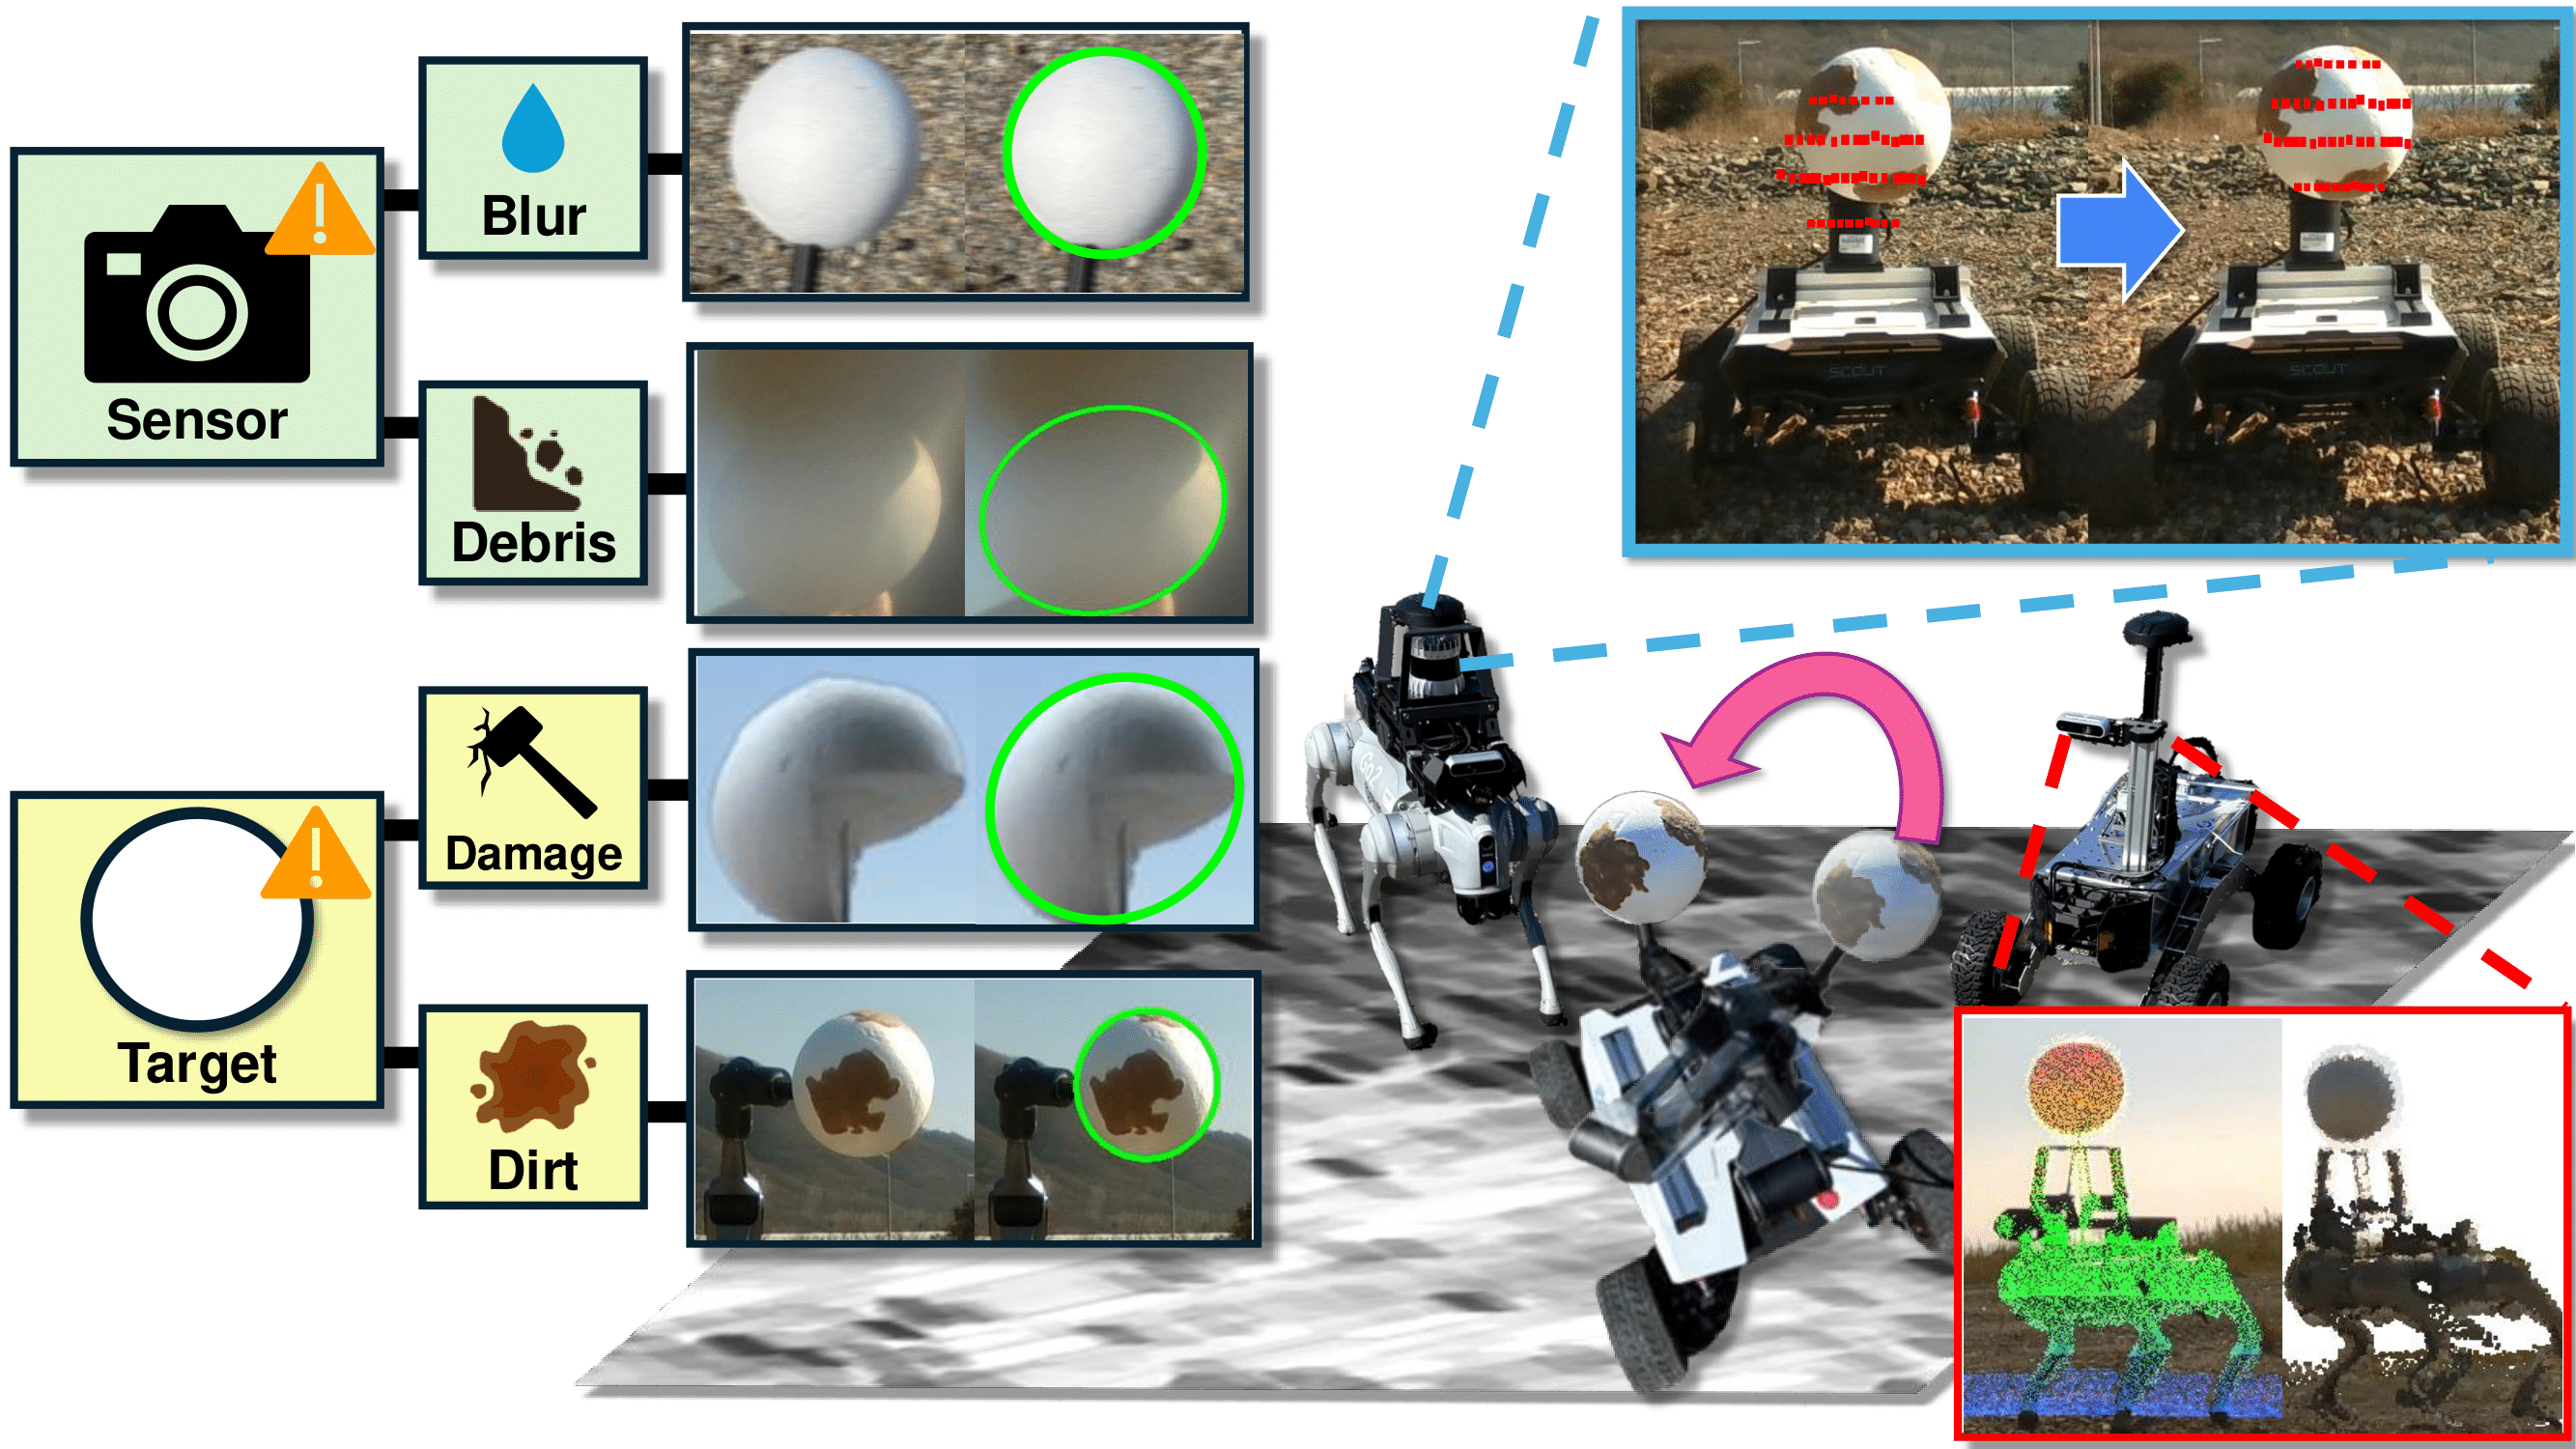
Multi-Robot, Spherical Target-based LiDAR-camera Calibration


ICRA Workshop on Field Robotics (ICRA-W 2025)
Spotlight Talk
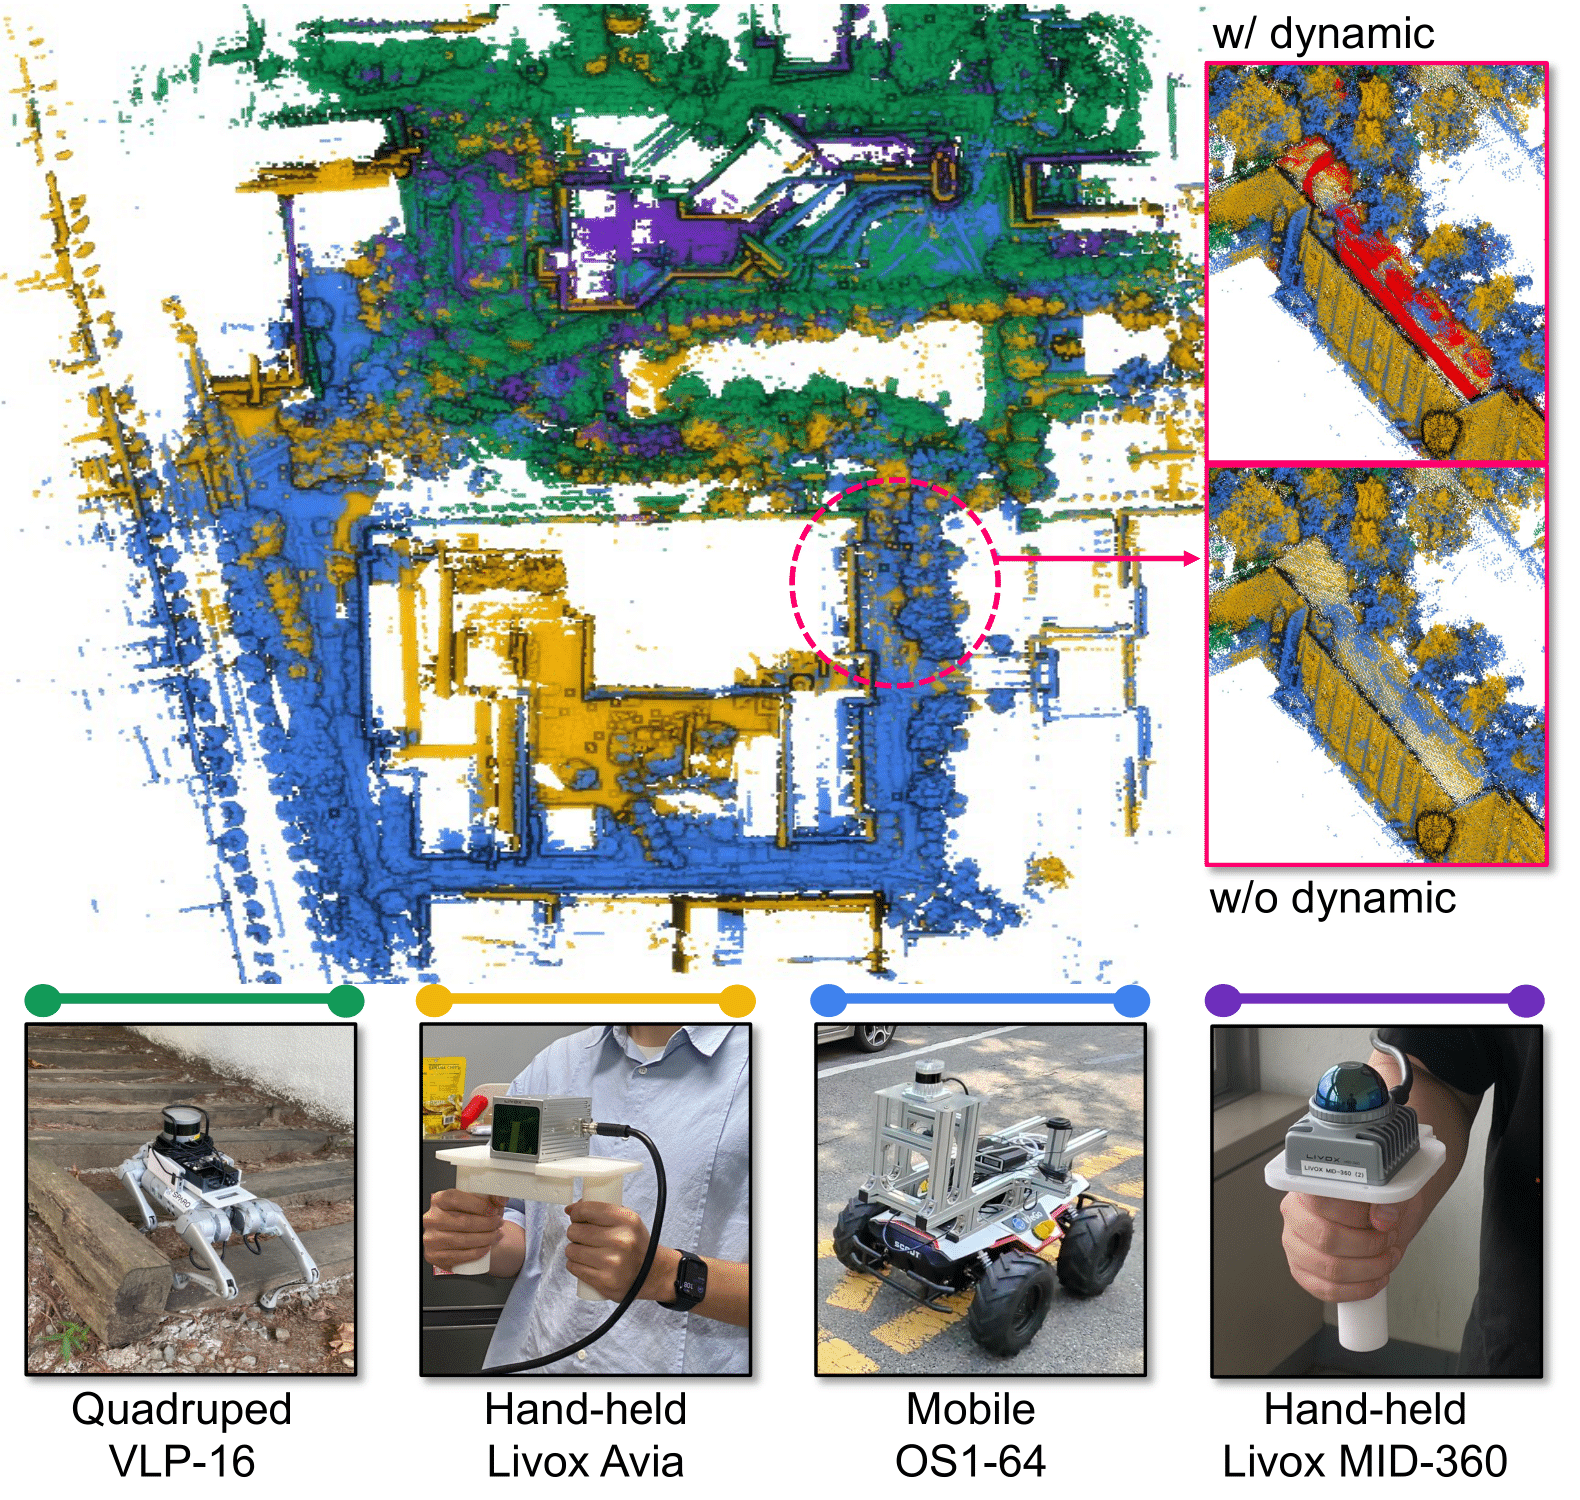
Multi-Robot and Distributed LiDAR SLAM Framework

IEEE Robotics and Automation Letters (RA-L 2024)
Lightweight LiDAR Place Recognition

IEEE Robotics and Automation Letters (RA-L 2024)
Lightweight Radar Place Recognition

IEEE Sensors Letters (2024)
Multi-Modal Legged Robot Datasets

No matching papers.
Projects
Research grants, challenges, and open-source projects.

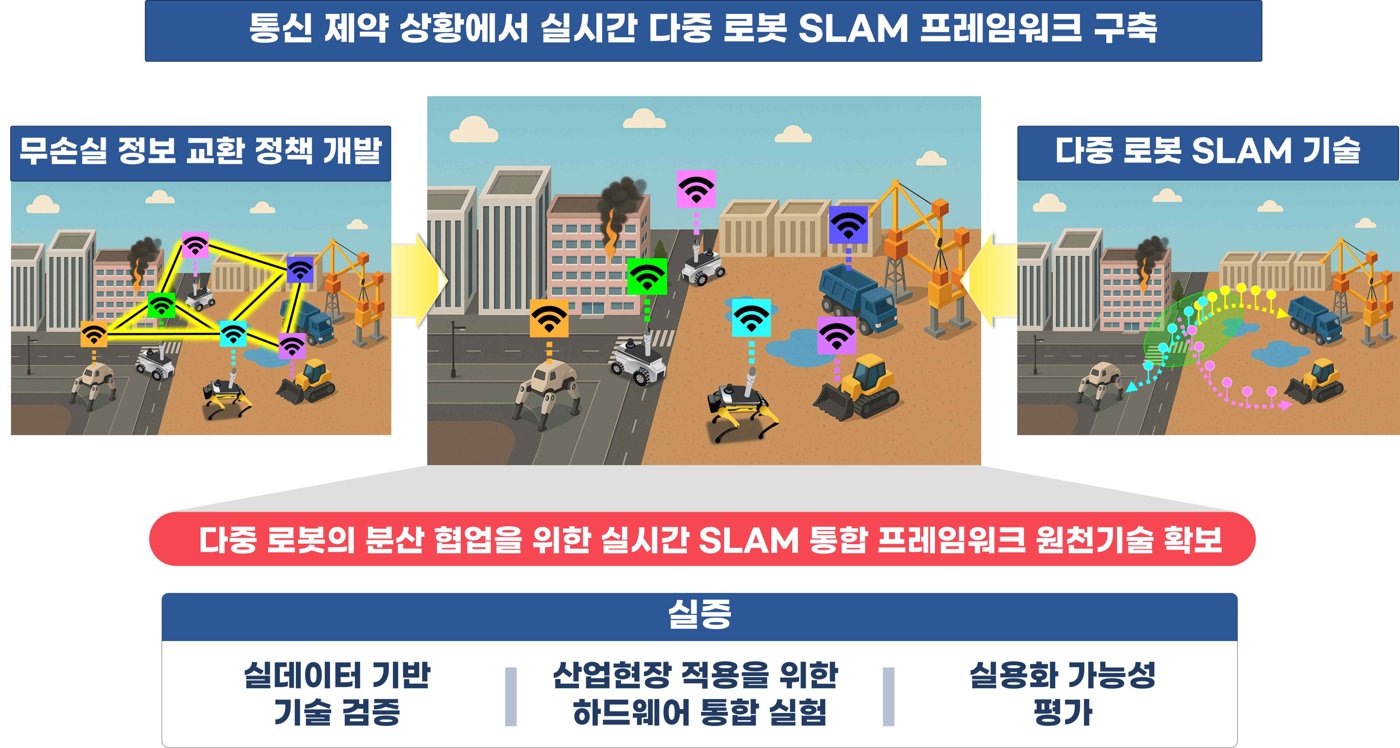
ν΅μ μ μ½ μν©μμ μ€μκ° λ€μ€ λ‘λ΄ SLAM νλ μμν¬ κ΅¬μΆ
National Research Foundation of Korea (NRF) · Ph.D. Candidate Research Fellowship
Most multi-robot systems assume reliable communication and break down under the delays, dropouts, and limited bandwidth of real sites. This project builds a multi-robot SLAM framework that keeps robots collaborating while exchanging only the minimum necessary information.

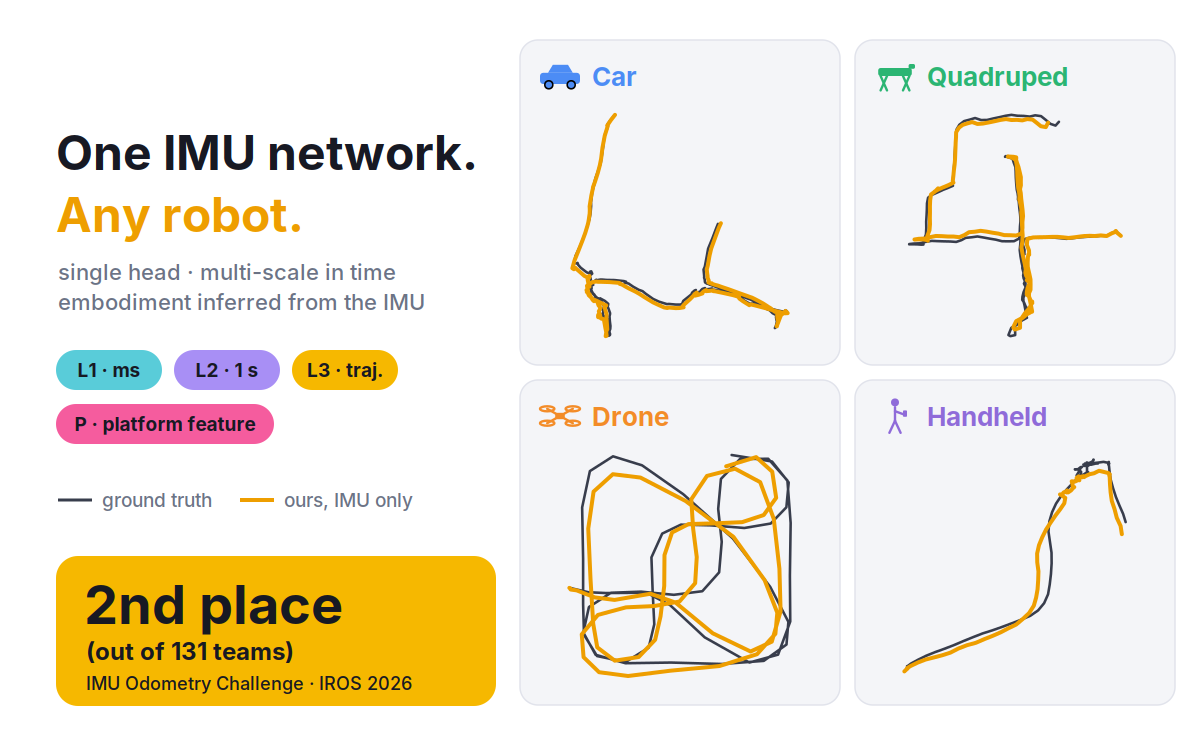
IMU Odometry Challenge · Beyond Exteroception Workshop, IROS 2026
2nd Place among 131 teams
Single-Head IMU Velocity Estimation Across Platforms via a Multi-Scale, Embodiment-Aware Encoder — one network that estimates velocity from IMU alone across cars, quadrupeds, drones, and handheld devices.

Workshop on Open Challenges in Robotics for Asset Inspection and Management, ICRA 2026
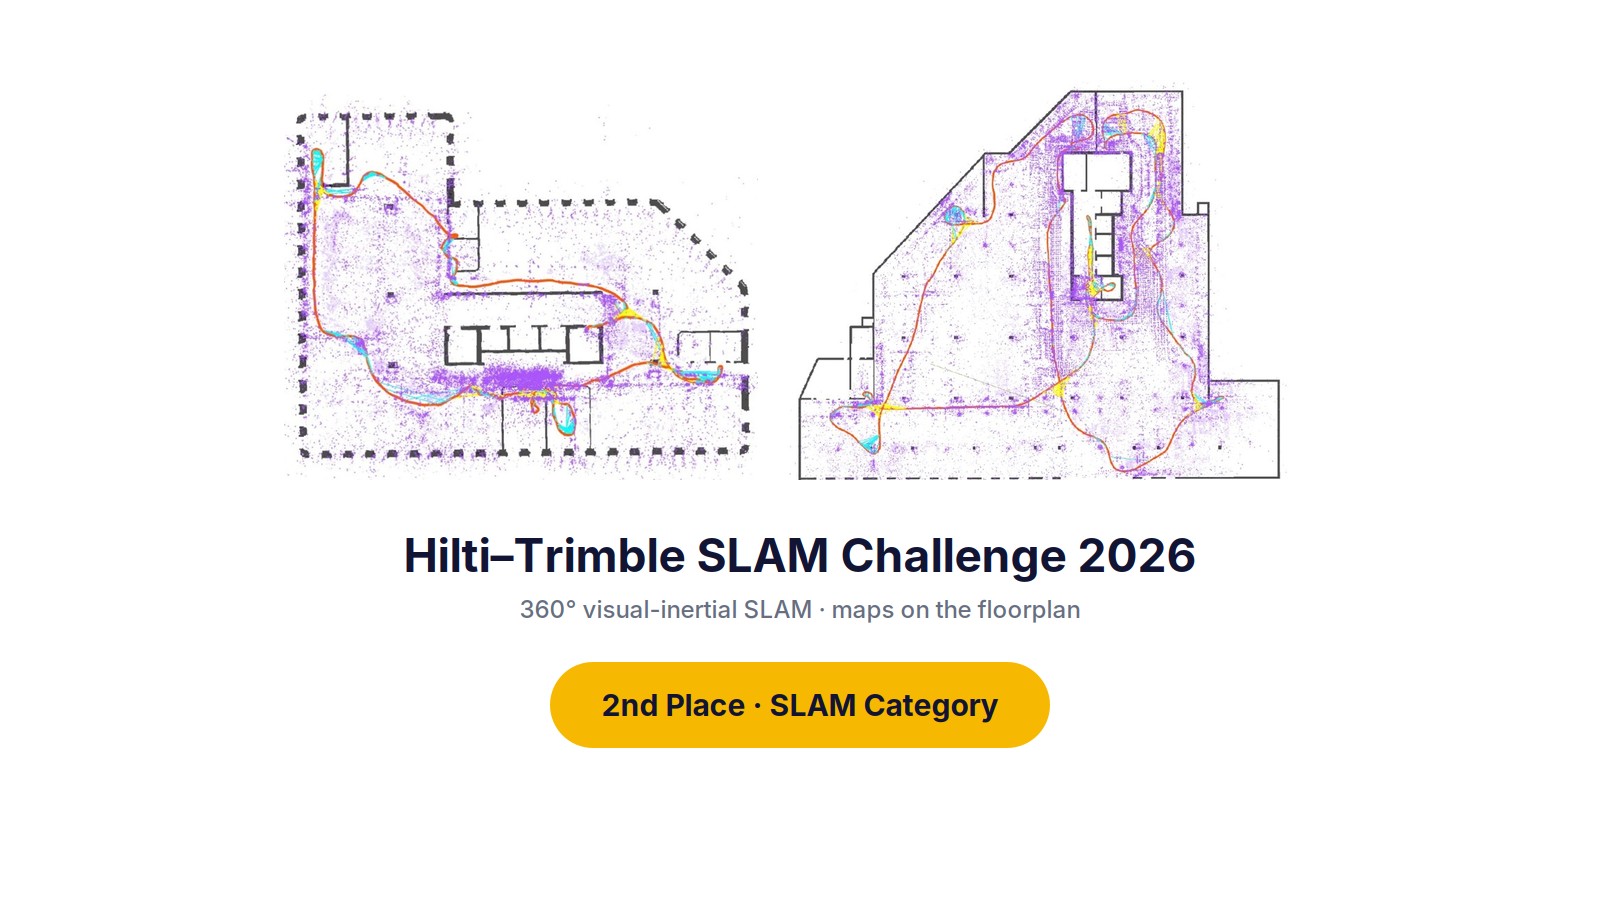
2nd Place, SLAM Category
√VINS-Based 360 Visual-Inertial SLAM Systems — a 360-camera visual-inertial SLAM pipeline for long indoor sequences with dark regions, repetitive corridors, and dynamic objects.

Personal Project · Curated List
A curated list of LiDAR place recognition research with code or download pages, covering handcrafted and learning-based methods, single-session, multi-session, and multi-robot datasets, and related algorithms such as multi-robot mapping and SLAM.
News
Papers, awards, and activities, newest first.
ETC
Invited presentations and peer-review service.
Talks
Service